
AKP342 High-Precision Vibration Sensor for Wind Turbine and Industrial Monitoring
APPLICATION
- Wind power generation monitoring
- Monitoring of bridges and dams
- Monitoring of ancient buildings
- High-speed rail monitoring
- Earth satellite communication vehicle
- Railway gauge, gauge leveling
- Satellite communication vehicle
- Geological equipment tilt monitoring
- Engineering vehicle leveling
WORKING PRINCIPLE OF VIBRATION
It adopts imported core control unit and uses the principle of capacitive miniature pendulum. According to the gravity principle of the earth, the gravity of the earth can generate a gravity component on a corresponding pendulum when the obliquity motion is inclined, the corresponding capacitance can be changed, and the acceleration can be obtained by amplifying, filtering and converting the capacitance. The frequency is obtained by algorithm processing and data analysis according to the collected acceleration. Amplitude data information.
INSTALLATION DIRECTION
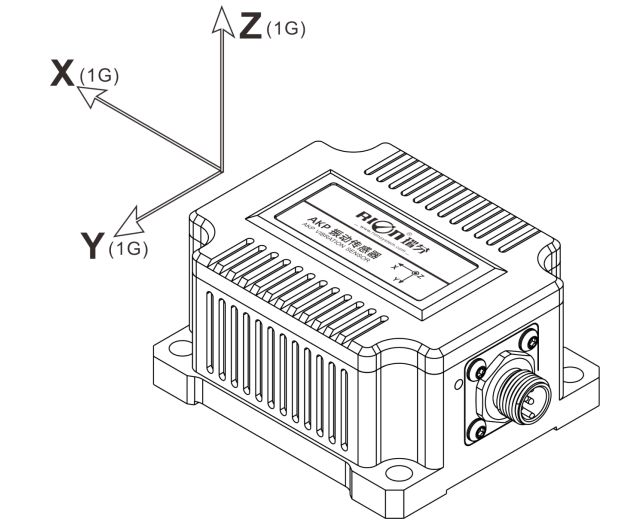
During installation, keep the mounting surface of the sensor parallel to the surface of the target to be measured, so as to reduce the influence of dynamic and acceleration on the sensor. This product can be installed horizontally or vertically. Please refer to the following schematic diagram for the installation method:
PRODUCTION INSTALLATION NOTES
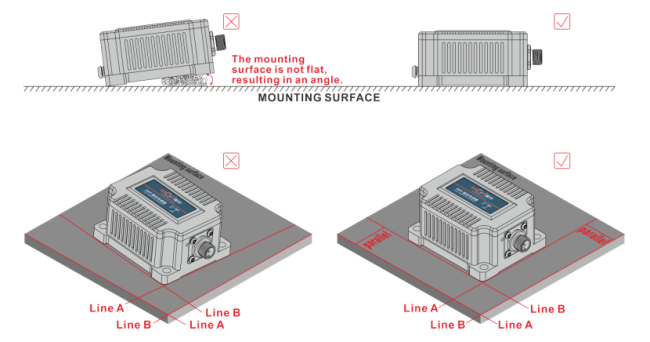
Please install the tilt sensor according to the correct method. Incorrect installation will lead to measurement errors. Pay special attention to one "surface" and two "lines":
- The mounting surface of the sensor and the surface to be measured must be fixed tightly, smoothly and stably. If the mounting surface is uneven, it is easy to cause the error of the included angle measured by the sensor.
- The axis of the sensor must be parallel to the axis to be measured, and the two axes should not form an angle as far as possible.
FEATURES
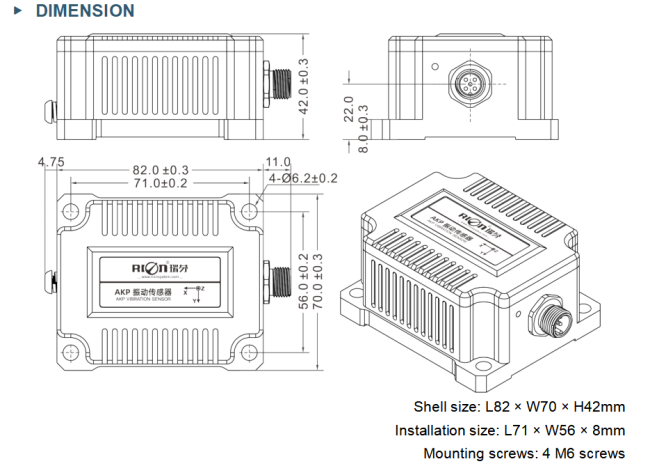
- Size: L82 * W70 * H42mm
- DC 9 ~ 36V wide voltage input
- Resolution 1ug
- IP 67 protection class
- Wide temp operation -40 ~ + 85 ℃
- Triaxial measurement
- Output mode RS485, RS422, RS232 optional
SPECIFICATIONS
| AKP342 | Parameter | Unit |
| Range | ±2 | g |
| Deviation calibration | <1 | mg |
| Measure axial direction | X,Y,Z | Shaft |
| Repeatability of power-up/power-down | <2 | Mg (Max) |
| Temp coefficient of deviation | 0.15 | Mg/℃ (typical) |
| Resolution | 1 | ug |
| Nonlinearity | <1 | % FS (Max) |
| Bandwidth (3DB) | 0.1~10 | Hz |
| Cross-axis sensitivity | 1 | % |
| Transverse vibration sensitivity ratio | 1 | % |
| Noise density | 21 | μg/√Hz |
| Resonant frequency | 2.4 | kHz |
| Acceleration power-up settling time | 1S | |
| FFT power-up settling time | 30S | |
| Output rate | 5Hz,10Hz,25Hz,35Hz,50Hz,100Hz | |
| Output interface | RS232/TTL/S485 | |
| Communication protocol | 68 Protocol and MODBUS RTU Protocol | |
| Input (VDD _ VSS) | 9~36 VDC | |
| Operating current consumption | <16mA @ 12 VDC | |
| Weight | ≤ 400g (excluding cable) | |
MECHANICAL PARAMETERS
- CONNECTORS: Aviation plug connector
- Degree of protection: IP67
- Shell material: aluminum alloy anodized
- Installation: four M6 screws
Get in Touch
Have questions about our products or want to discuss a custom order? Our team is ready to help you.