
LKF-MSI105 MEMS Inertial Navigation System with 500°/s Gyro
The LKF-MSI105 MEMS Inertial Navigation System is a compact, cost-effective solution designed for navigation, control, and measurement applications, particularly for drones and other mobile platforms.
This integrated navigation system combines a GNSS satellite receiver and information processing functions on a single chip with a built-in IMU. It captures real-time angular rate and acceleration data while receiving GNSS satellite signals from dual antennas or track angles, computing heading angle, three-dimensional velocity, position, and attitude information.
The system features full-temperature zero-point and scale compensation for the internal IMU module, ensuring reliable performance. Based on receiver functionality, it maintains positioning accuracy during short-term satellite outages and attitude accuracy during medium to long-term satellite outages.
- High performance with small size and low weight
- Supports GNSS full frequency points with high positioning and orientation accuracy in complex environments
- Steady-state operation at 0.5W ultra-low power consumption
- -45℃ to +80℃ full temperature calibration compensation
- Adaptive attitude algorithm optional
- Software online upgrade function with arm error compensation
- Self-correction algorithm when GNSS is unavailable, maintaining horizontal attitude accuracy
- RTK differential connectivity
- Multi-IMU redundancy capability
- Dynamic Communication
- Position and attitude reference for drones, vehicles, ships, and boats
- Attitude Control
- Drones and Unmanned Ships
|
MEMS Gyroscope |
|
|
Range (°/s) |
±500 |
|
Bias@ Full temp.(°/h) |
≤360 |
|
Bias Stability (°/h, 10s smoothing) |
≤10 |
|
Bias Instability (°/h, Allan) |
≤3 |
|
Bias Repeatability (°/h) |
≤10 |
|
Angle Random Walk (°/√h) |
≤0.3 |
|
Scale Factor Nonlinearity (ppm) |
≤100 |
|
Cross-coupling (rad) |
≤0.001 |
|
Bandwidth (Hz) |
≥100 |
|
MEMS accelerometer |
|
|
Range (g) |
±16 |
|
Bias (mg) |
≤3 |
|
Bias Stability (ug, 10s smoothing) |
≤ 300 |
|
Bias Stability (ug, Allan) |
≤ 50 |
|
Bias Repeatability (ug) |
≤ 300 |
|
Velocity Random Walk (mm/s/√h) |
≤ 50 |
|
Scale Factor Nonlinearity (ppm, ±1g) |
≤ 300 |
|
Cross Coupling (rad) |
0.001 |
|
Bandwidth ( Hz ) |
≥100 |
|
Combined Navigation Accuracy |
|
|
Combined Heading (°, 1σ, Real-time) |
0.2 (1m baseline dual antenna) 0.5 (single antenna, dynamic) |
|
Combined Horizontal Attitude (°, 1σ, Real-time) |
0.1° (dual antenna), 0.2° (single antenna) |
|
Combined Horizontal Position (m, 1σ) |
3m (single point), 0.0 2 +1ppm (RTK) |
|
Combined Vertical Position (m, 1σ) ) |
5m (single point), 0.0 3 +1ppm (RTK) |
|
Combined horizontal speed (m/s, 1σ) |
0.1 |
|
Combined vertical speed (m/s, 1σ) |
0.15 |
|
Electrical/mechanical interface |
|
|
Power supply (V) |
5V |
|
Steady-state power (W) |
≤0.5 |
|
Startup time (s) |
≤3 |
|
Communication Interface |
2*LVTTL Level UART Interface, LVTTL Level PPS Synchronous Output, 1*LVTTL Level IMU Acquisition Synchronous Output |
|
Maximum Update Rate (Hz) |
100 |
|
Dimensions (mm×mm×mm) |
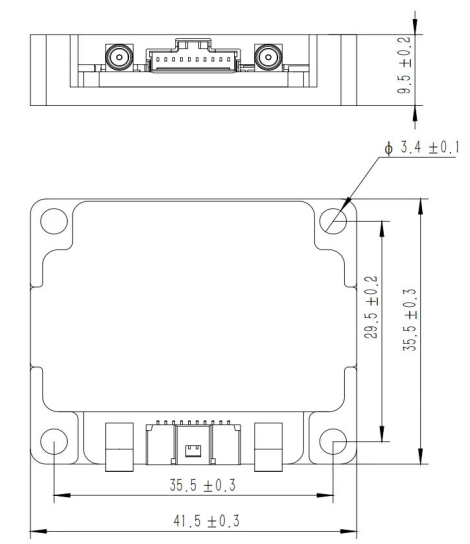
41.5×35.5×9.5 |
|
Weight (g) |
<50 |
|
Operating Environment |
|
|
Operating Temperature (℃) |
-40~+85 |
|
Storage temperature (℃) |
-55 to +85 |
|
Vibration (g, Rms) |
20~2000HZ, 4.08 |
|
Shock (g) |
1000g/1ms |
|
Reliability |
|
|
MTBF (h) |
10000 |

Get in Touch
Have questions about our products or want to discuss a custom order? Our team is ready to help you.