
SYT-RI40-52
Price:
Negotiable
MOQ:
Negotiable
Delivery Time:
Negotiable
Brand:
SENINTER
Product Description
Drawing without brake
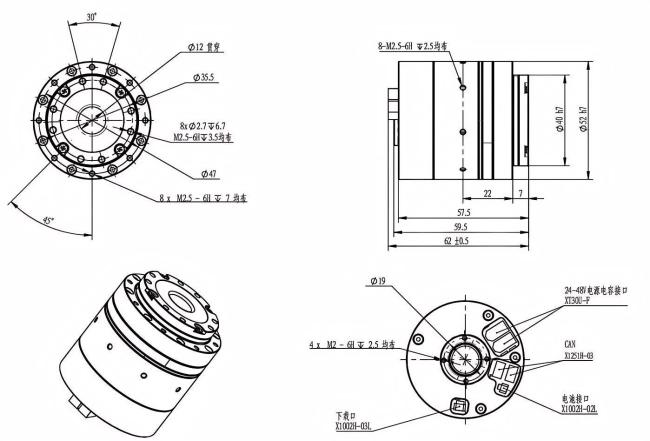
without brake Parameter Table
| Parameter | Unit | Ratio 51 | Ratio 101 |
| Gear Ratio | - | 51 | 101 |
| Peak Torque | N·m | 8.3 | 11 |
| Max Allowable Torque At Average Load (Robot Application) | N·m | 5.5 | 8.9 |
| Rated Torque @ 2000RPM (Industrial Application) | N·m | 3.5 | 5 |
| Peak Output Speed | RPM | 118 | 59 |
| Rated Speed (With 1/2 Rated Torque) | RPM | 80 | 40 |
| Gear Backlash | arcsec | 40 | 30 |
| Rated Power | W | 90 | 90 |
| Supply Voltage | V | 24–48 | 24–48 |
| Max Continuous Current | A | 3 | 3 |
| Rated Current | A | 2 | 2 |
| Torque Constant | N·m/A | 0.05 | 0.05 |
| Encoder Resolution | bit | 16 | 16 |
| Communication Bus | - | CAN | CAN |
| Hollow Shaft Diameter | mm | 12 | 12 |
| Total Length | mm | 62±0.5 | 62±0.5 |
| Mass | kg | 0.32 | 0.32 |
| Rotational Inertia | g·cm² | 73 | 73 |
Drawing with brake
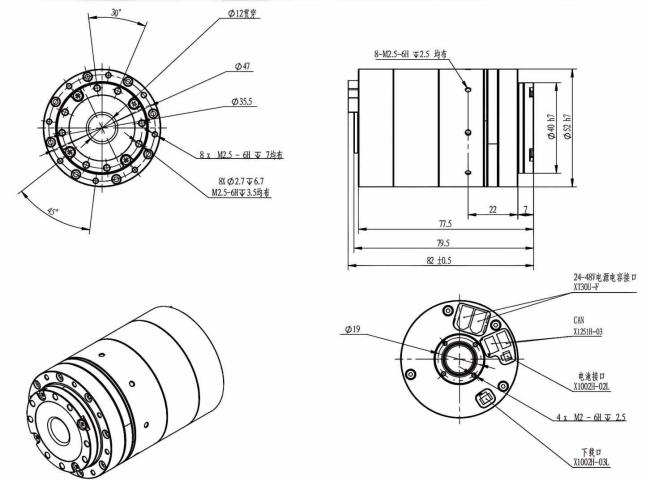
With brake Parameter Table
| Parameter | Unit | Ratio 51 | Ratio 101 |
| Gear Ratio | - | 51 | 101 |
| Peak Torque | N·m | 8.3 | 11 |
| Max Allowable Torque At Average Load (Robot Application) | N·m | 5.5 | 8.9 |
| Rated Torque @ 2000RPM (Industrial Application) | N·m | 3.5 | 5 |
| Peak Output Speed | RPM | 118 | 59 |
| Rated Speed (With 1/2 Rated Torque) | RPM | 80 | 40 |
| Gear Backlash | arcsec | 40 | 30 |
| Rated Power | W | 90 | 90 |
| Supply Voltage | V | 24–48 | 24–48 |
| Max Continuous Current | A | 3 | 3 |
| Rated Current | A | 2 | 2 |
| Torque Constant | N·m/A | 0.05 | 0.05 |
| Encoder Resolution | bit | 16 | 16 |
| Communication Bus | - | CAN | CAN |
| Hollow Shaft Diameter | mm | 12 | 12 |
| Total Length | mm | 82±0.5 | 82±0.5 |
| Mass | kg | 0.42 | 0.42 |
| Rotational Inertia | g·cm² | 116.2 | 116.2 |
Similar Products
Get in Touch
Have questions about our products or want to discuss a custom order? Our team is ready to help you.
Company
Shenzhen Seninter Precision Machinery Co.,Ltd.
Location
Shenzhen, Guangdong, P.R.China
Contact Person
Tony-yin